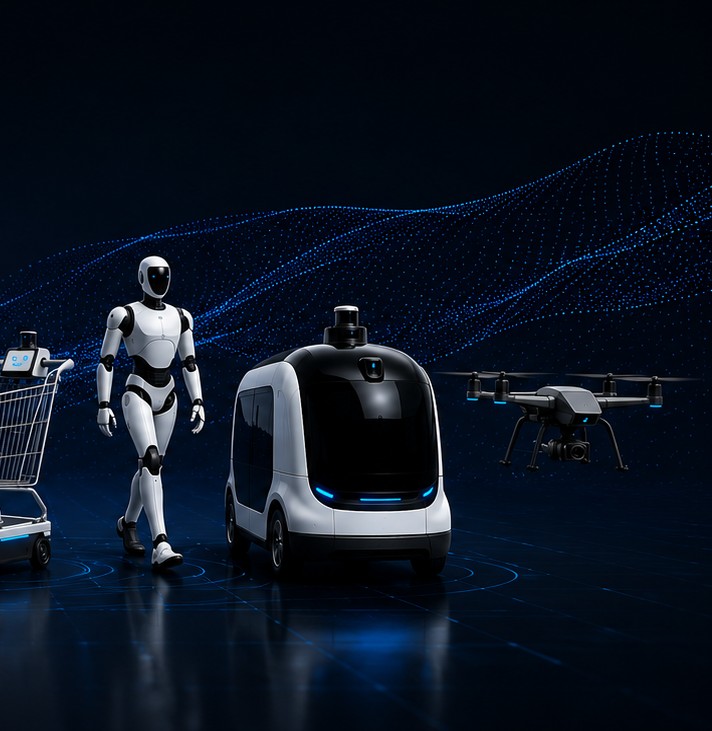
Deployment efficiency
The first production build took years. The next took a fraction of that. Each integration turns bespoke engineering into repeatable process.
The spatial intelligence layer for Physical AI
One platform today. The data and intelligence tomorrow. RobotZ gives robot makers a production-ready navigation stack, so nobody has to build one from zero.
The problem
Localization, mapping, perception, planning, control — the same stack, rebuilt from scratch by every team that wants a robot to move through the physical world. It is the single largest tax on getting robots into production.
Building navigation independently, each solving the same problems in isolation.
To get production-grade navigation working in-house — before a single unit ships.
The engineering bill for a stack that is table stakes, not differentiation.
Five years, twenty engineers and roughly $22M to put automotive-grade autonomous parking into production, indoors and outdoors. That work became the platform. Nobody after us has to repeat it.
The platform
A navigation core that runs on the sensors you already chose, the robot you already designed and the environment you actually operate in — connected to a learning network that improves with every deployment.
Camera, LiDAR, ultrasonic, IMU, wheel odometry — and combinations of them.
Four-wheel platforms, carts, quadrupeds, humanoids — the same core, re-tuned.
Indoor, outdoor, structured and unstructured — including crowded human spaces.
Localization · Mapping · Perception · Planning · Control. One stack, tuned per robot instead of rebuilt per robot.
Shared data, shared maps, shared models. Every deployment feeds capability back into the platform.
Typical integration to production runs 3–6 months instead of a 2–3 year in-house build.
Engineered to run on cost-appropriate compute, so unit economics work at volume.
Reliability and coverage improve as the fleet grows, without you rewriting code.
Time and cost ranges reflect RobotZ deployments to date. Actual figures depend on robot, sensors and operating design domain.
Deployments
The platform was hardened where the bar is highest — automotive production programmes, with the reliability and validation discipline that implies. It is now moving into robots that work alongside people.
Production programmes with a leading Chinese automotive OEM and, via a global Tier-1 supplier, a second OEM. Vehicles locate themselves and park autonomously across multi-storey garages and open lots.
The same navigation core, re-targeted to a new embodiment and a dense, unpredictable human environment: in-store guidance, aisle-level positioning and routing to products.
Each new environment adds capability the whole platform inherits. If you are building a robot that has to move through one of them, we would like to hear about it.
Why a platform wins
A shared platform is not just a cost saving. Three things compound with every robot that runs on it — and they compound for everyone on the platform at once.
The first production build took years. The next took a fraction of that. Each integration turns bespoke engineering into repeatable process.
Every customer adds an embodiment, a sensor set or a scene. The next customer inherits it without paying for it.
Same code, more real-world hours: localization accuracy improves, intervention rates fall, corner-case coverage grows.
This data is generated only by robots operating in the physical world. It does not exist on the internet.
The edge cases that matter emerge around real people, in real environments, under real hardware constraints.
Deployment history accumulates customer by customer, over time. Starting three years late means three years of missing experience.
Why now
Demand for robots already exists. What has changed is supply: capable sensing and compute at prices that work in a product, and models good enough to handle messy environments. In every previous platform shift — PCs, mobile — affordable hardware came first, applications exploded next, and the shared platform layer underneath captured a durable share of the value.
Navigation is that layer for robotics. We are building it while deployments are still customer-funded, because the operating experience it produces can only be accumulated ahead of the wave, not after it.
Sensing, compute and models now clear the bar for real deployments.
Hardware cost curves make production robots commercially viable.
New robot categories appear faster than any one team can build a stack for.
Why us
Our team has done this twice before: consumer navigation on roughly 100 million phones, then connected-car navigation across roughly 50 million vehicles. Both times the work was the same — take a hard spatial problem and make it reliable, cheap and repeatable at scale.
Meet the team →Mobile navigation, pioneered a decade before it was standard.
Navigation delivered at automotive scale and reliability.
Three generations of navigation, one discipline.
Founding team took its previous navigation company public.
Tell us what you are building and which environment it has to survive. We will tell you honestly whether the platform fits today.